FARM: Find Anything using Relational Spatial Memory
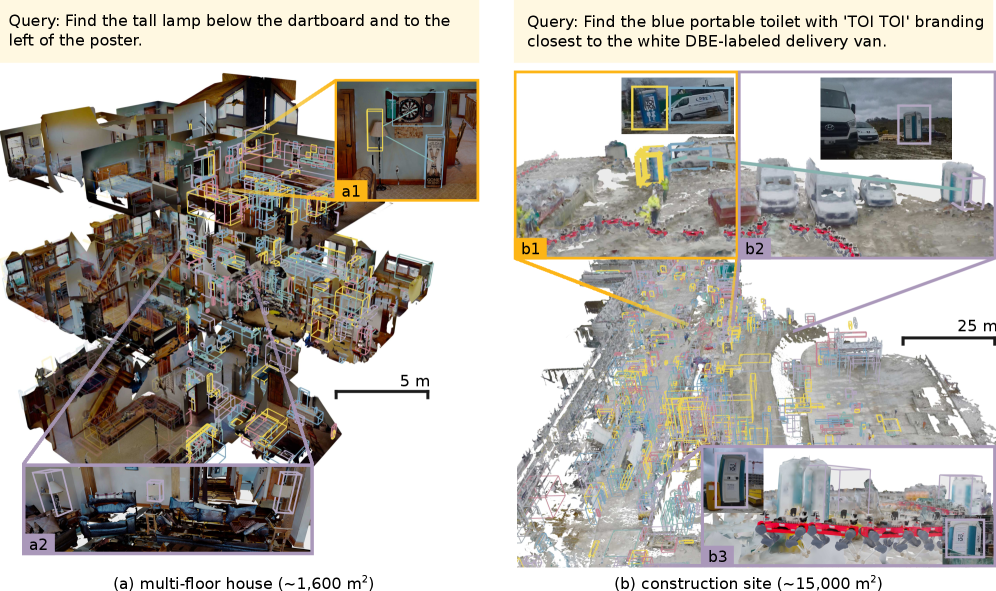
Robots in large, object-rich spaces need a persistent spatial memory and the ability to retrieve a specific object instance from natural language that refers to it through relations to landmarks, such as "the tall lamp below the dartboard and left of the poster." Prior systems require offline processing, fixed vocabularies, or struggle with compositional spatial reasoning.
FARM builds an online, object-centric scene graph in real time (5–10 Hz), storing geometry, vision-language descriptors, and viewpoint evidence per object. At query time, an LLM parses the instruction into a symbolic specification with spatial predicates; soft evaluators score candidate bindings against memory; and a VLM reranks the top candidates by inspecting projected views, giving structured reasoning over noisy, metric data.
- Real-time, scale-invariant mapping Online scene-graph construction from indoor rooms to 15,000 m² outdoor sites under one fixed hyperparameter setting, with no offline post-processing.
- Predicate + VLM retrieval Structured spatial-predicate evaluation combined with VLM verification, for +164% Recall@5 and +224% Recall@10 over prior methods.
- FARM-Scenes benchmark Seven large indoor/outdoor scenes (1,800–15,000 m²) with 44k annotated relational language queries.
- Closed-loop robot deployment Demonstrated on a quadrupedal robot using onboard sensors and compute.
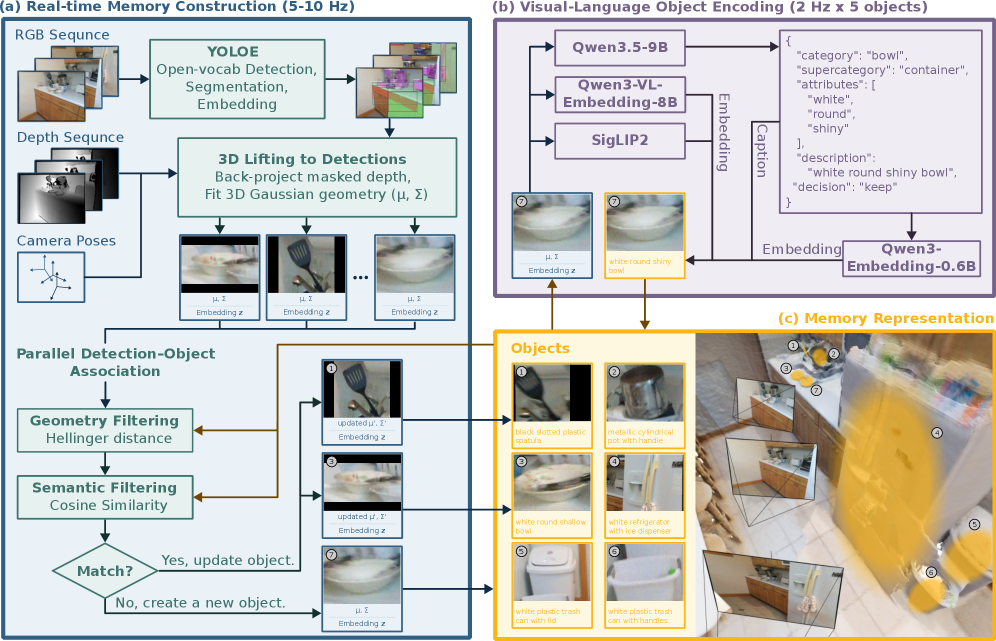
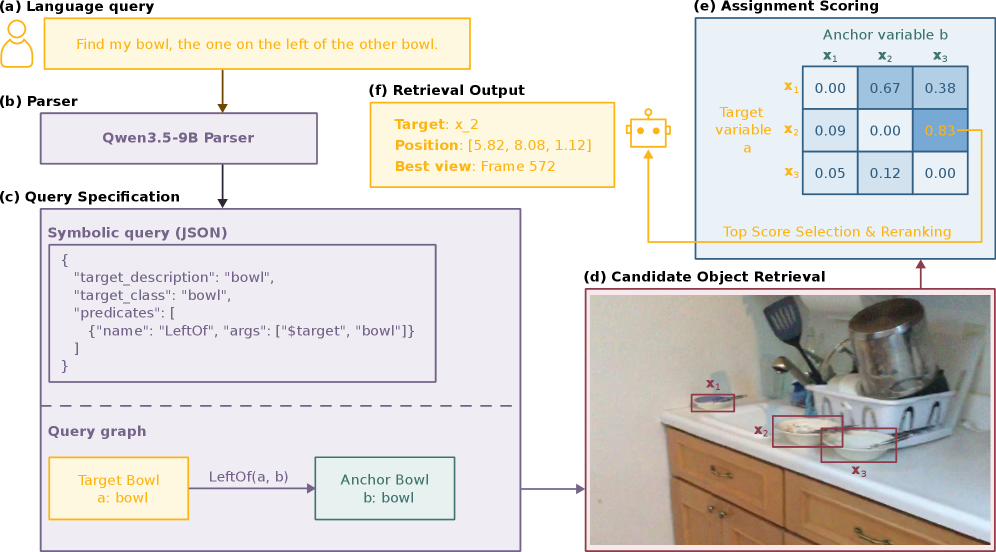
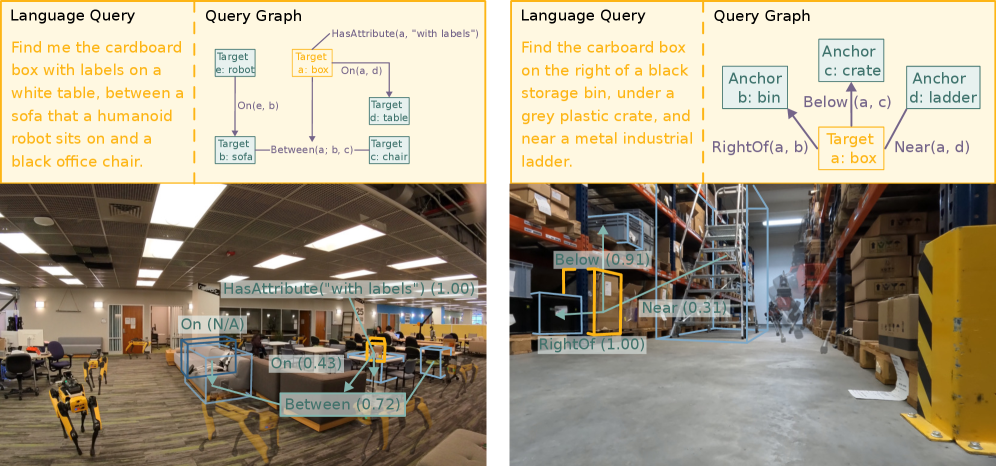
FARM works across ScanNet, HM3D, and outdoor construction, warehouse, and museum environments, pointing toward robots that can take an everyday relational instruction and act on it in the messy, open world.
A collaboration between Stanford University (Autonomous Systems Lab) and UC Berkeley.
Siming He
Leo Huang · Adam Lilja · Jonas Frey
Fabio Hübel
Marco Pavone
S. Shankar Sastry · Jitendra Malik · Claire Tomlin
- He, Huang, Lilja, Hübel, Frey, Pavone, Sastry, Malik, Tomlin. "FARM: Find Anything using Relational Spatial Memory." Under review. arXiv:2606.15476.