Learning-Based Reward Functions for Improved Autonomous Navigation in Confined Terrains
Efficient autonomous navigation in unknown and confined terrains remains challenging, but crucial for robust robotic exploration and inspection tasks. Current approaches struggle due to the inherent difficulty in navigating unfamiliar environments; a capability humans and animals intuitively develop through experience. While learning-based methods can mimic such intuition, they usually require extensive labeled data, resulting in poor sample efficiency, particularly under sparse supervision. This project proposes a self-supervised, learning-based approach that leverages environmental scans to generate effective supervisory signals.
Anton Pollak
Fabio Hübel
Dr. Jonas Frey
Pascal Roth
Dr. Cesar Cadena
Professor Marco Hutter
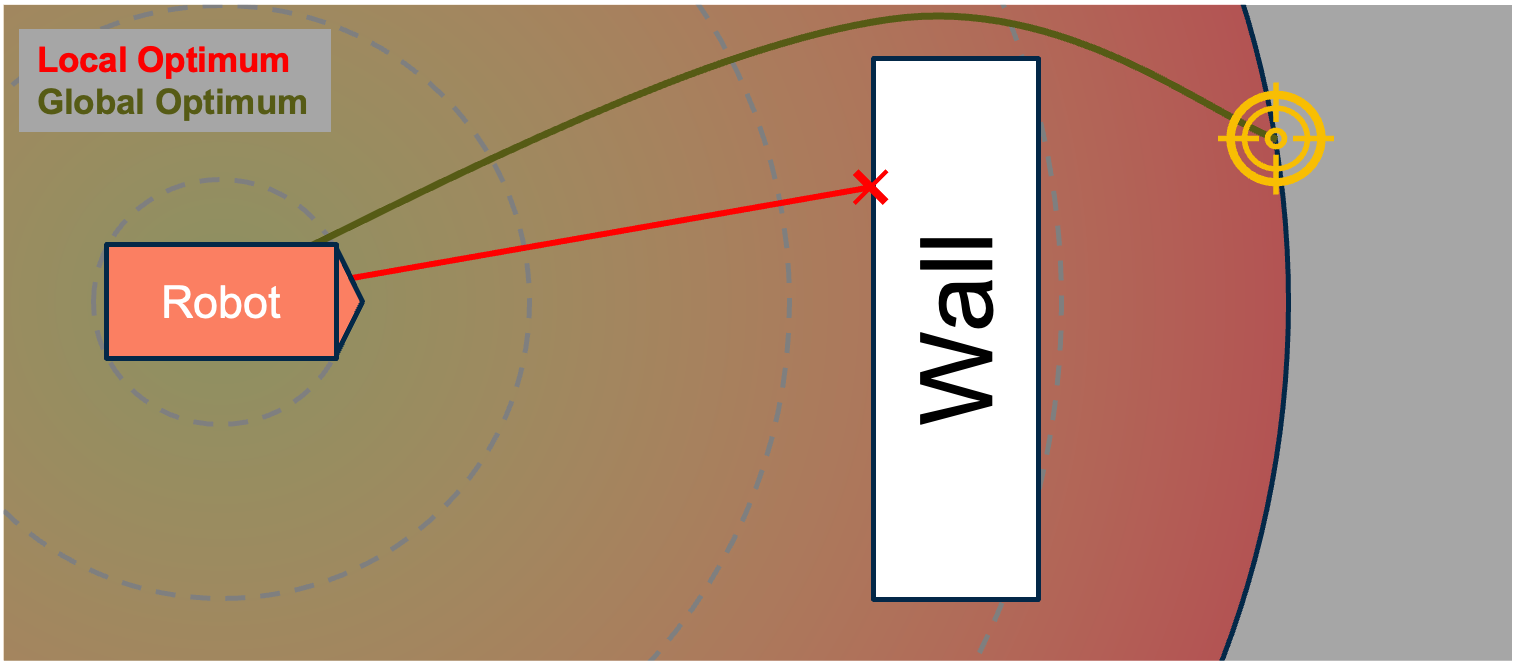
Expected Impact: This work presents a promising new perspective on planning and navigation challenges in robotics. Future directions include generalizing the approach across diverse scenarios through large-scale dataset generation in IsaacSim. If successfully generalized, this optimization-based approach could significantly advance autonomous navigation capabilities in complex, dynamic environments.