Real World Robotics
This project developed a low-cost, anthropomorphic robotic hand system specifically engineered for efficient data collection using data gloves for imitation learning on manipulation tasks. The 16 DOF (Degrees of Freedom) tendon-driven robotic hand features integrated force sensors in each fingertip and a sophisticated control system that enables precise teleoperation through human hand motion capture.
The system addresses key challenges in imitation learning research: the high cost of dexterous robotic hands and the difficulty of collecting high-quality expert demonstration data. By combining innovative mechanical design, advanced control algorithms including retargeting and Gaussian Process modeling, and streamlined data collection workflows, the project enables researchers to focus on developing capable control policies rather than struggling with hardware limitations and data quality issues.
- Low-Cost Anthropomorphic Design 16 DOF tendon-driven hand with 3D-printed components and integrated force sensors achieving minimal sensing force of ~49mN through custom silicone fingertips
- Precise Teleoperation System Real-time retargeting (8-20ms) of human hand poses using Rokoko smart gloves with Gaussian Process compensation for kinematic non-linearities
- Efficient Data Collection Pipeline Increased data collection throughput from 5 to over 75 samples per hour through GUI-based workflow management and automated calibration
Florian Lange
Anton Pollak
Richard Kuhlmann
Jaú Gretler
Sai Bommisetty
Rajiv Bhardawaj
Fabio Hübel
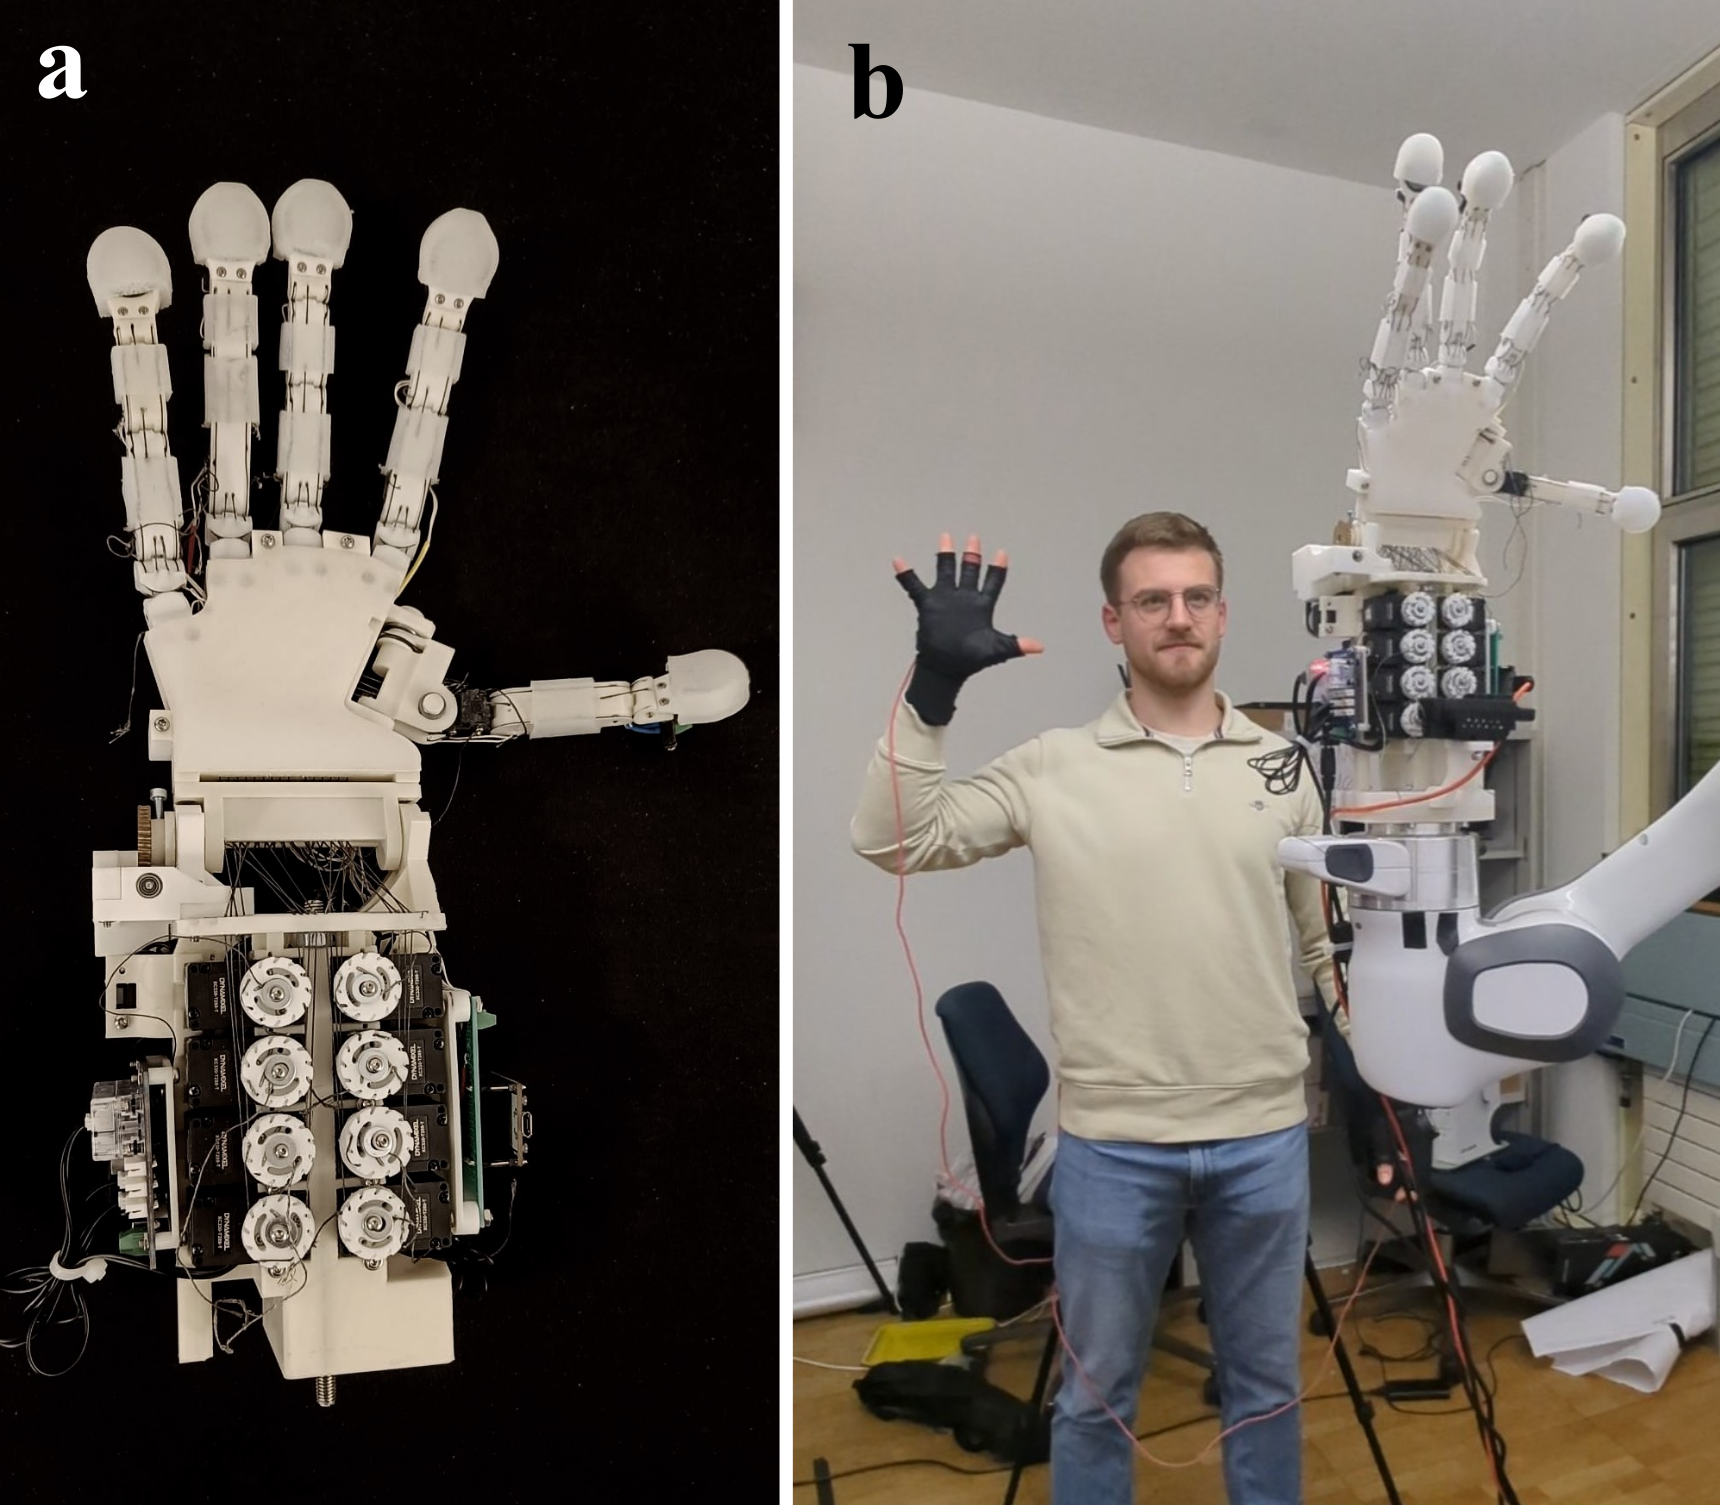
b: Robotic Hand in teleoperation
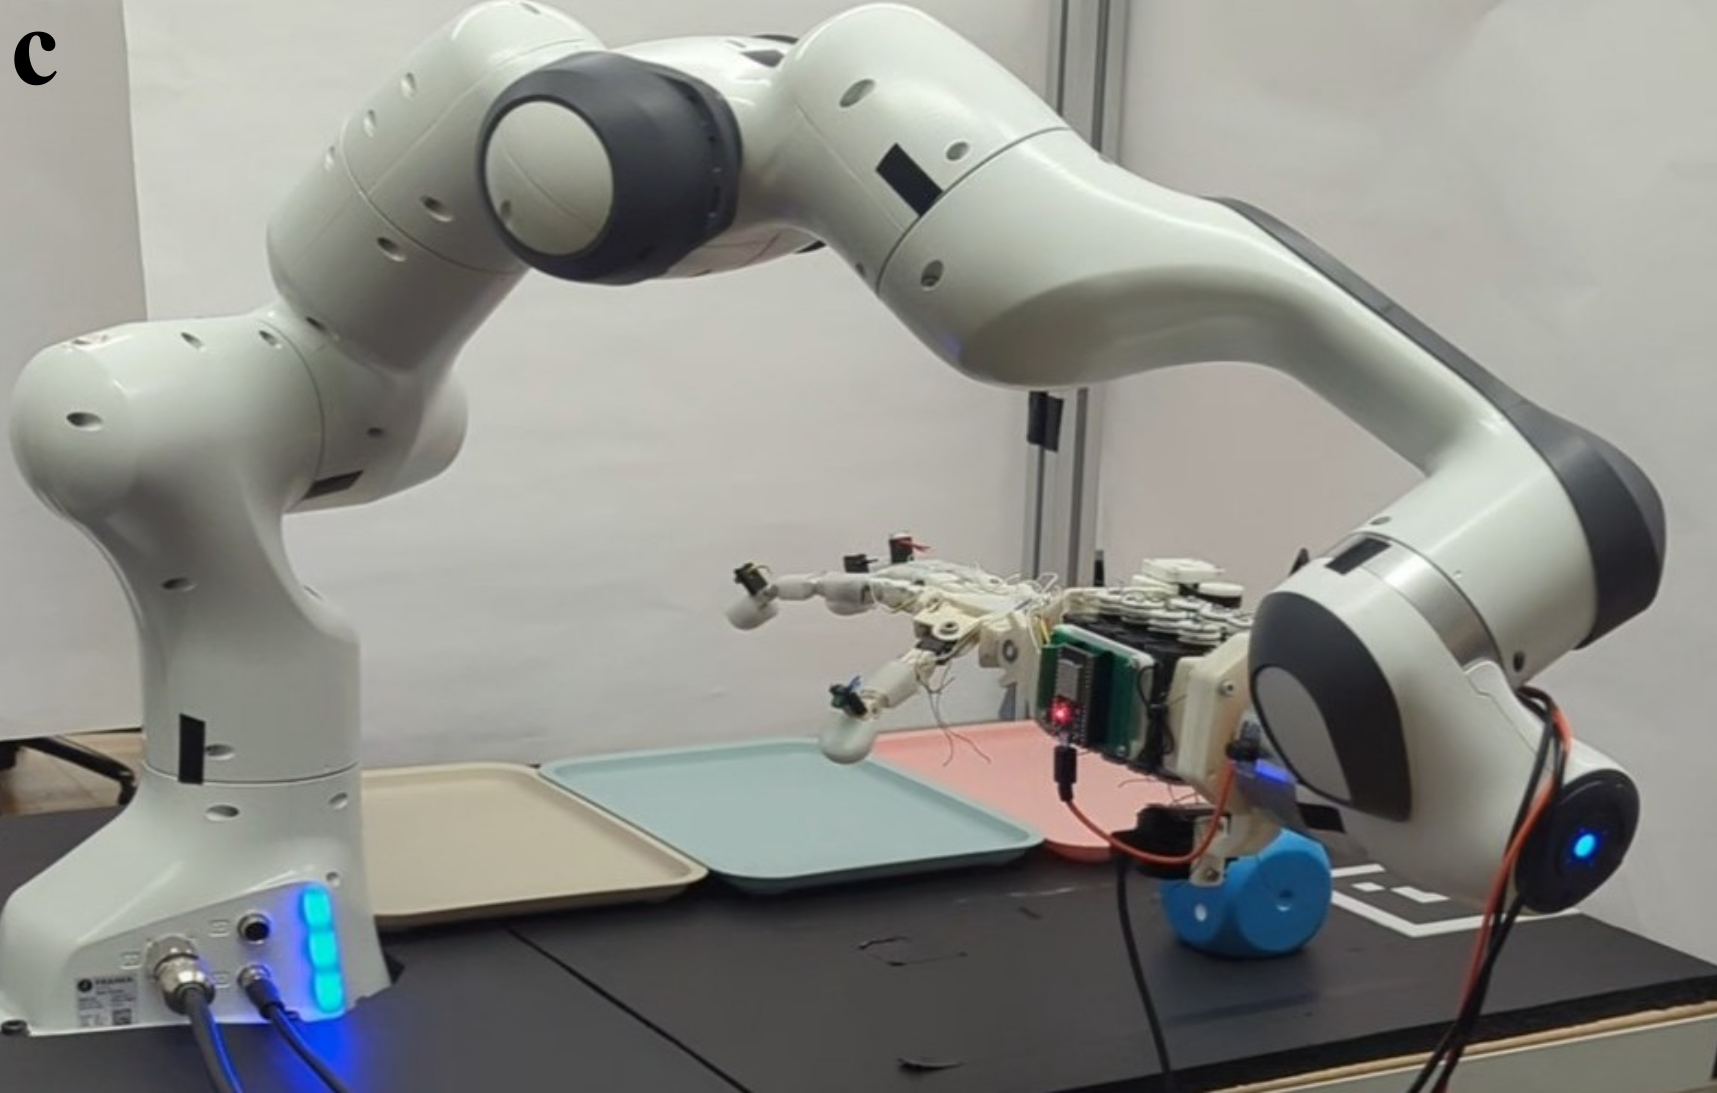
Results: The system demonstrated improved data collection efficiency and successfully enabled training of an autonomous color-based cube sorting policy deployed on a FRANKA manipulator. The retargeting system achieved real-time performance and high precision, while the custom force sensors achieved sensitivity down to 49mN, enabling detection of light touches crucial for manipulation tasks.
Impact: This work lowers the barrier to entry for imitation learning research by providing an affordable, capable platform for collecting expert demonstrations. The modular design and open architecture enable adaptation to various manipulation tasks and research applications. The improved data collection efficiency and quality directly translates to faster iteration cycles and better performing learned policies.